Author: Petr Šícho | Advisor: Daniel Wenz | Supervisor: Dimitrios Karampinos | Institution: CIBM, EPFL
Project Overview & Objective
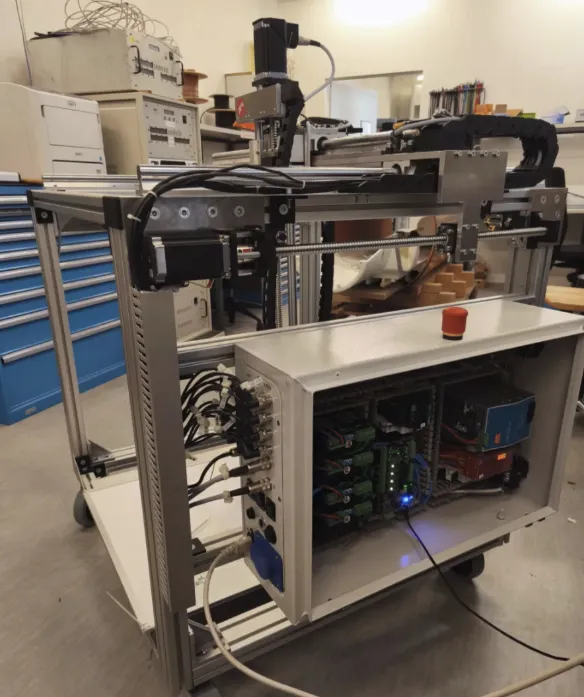
- Objective: Built and integrated an open-source robotic system for automated ultrasound and electromagnetic-field measurements over large volumes for Center of Biomedical Imaging (CIBM) at EPFL. Performed The goal was to achieve a very high positioning precision (0.01 mm) at a fraction of commercial alternative costs.
Mechanics & Structure
- Rigidity Enhancement: Added an extra aluminum profile to form a fully enclosed 12-edge cube to support heavy water-filled tanks.
- Workspace Optimization: Rotated the Z-gantry orientation to eliminate X-axis collisions and expand physical travel clearance.
- Dual X-Axis Drive: Upgraded with dual stepper motors, mirrored rails, and threaded rods to reduce backlash in X axis.
Electronics & Safety Architecture
- Control Stack: RUMBA32 main control board running customized Marlin 3D printer firmware (G-code parsing) connected to a Raspberry Pi.
- Safety Systems: Integrated XPSUDN13AP safety relay, physical emergency kill switch, dual hardware/software inductive endstops (16 total), and overcurrent/phase-loss motor protection.
- Power Management: Master power switch disconnecting low-voltage electronics (Rumba/RPi) and isolated 24V/5V circuit breakers.
Testing
- Tested electronical and mechanical parts, characterized positioning precision and repeatability,
Results
- Integrated a hydrophone probe, and developed software for automated data acquisition
- Positioning Precision: Achieved approximately 10 microns positioning precision over a 750 × 550 × 600 mm scanning volume
- Machine was successfully used for characterization of ultrasound fields of transducer and autonomously worked for several hours without direct supervision.